澳门大学团队攻克机器人抓取难题:新框架让不同型号机械手零样本稳定抓取,成果登《自然·机器智能》
澳门大学工程系教授徐青松带领的研究团队在通用机器人操作领域取得突破。团队开发出一套通用机器人抓取综合框架,可适配复杂场景,让定制的与商用的机械手快速上手部署,为柔性自动化生产、医疗辅助机器人与服务机器人提供新的技术方案。研究成果已发表于国际期刊《自然·机器智能》(Nature Machine Intelligence)。
团队指出,随着智能服务机器人在越来越多场景部署,现有操作算法有两个问题制约大规模商用:一是跨硬件平台适应性不足,二是在感官信息有限的复杂环境中稳健性差。依赖单目深度视觉的传统深度学习模型,难以准确刻画机械手与物体之间的物理接触,在不同型号的多指、多自由度机械手上做抓取任务时,泛化能力明显受限。
为解决这一难题,团队把机械手的运动学模型与操作过程中的交互接触状态解耦,建立与具体机械手型号无关的接触状态特征,并利用已有的成对抓取数据集,构建了大规模的非设备依赖接触特征数据库,再训练神经网络从视觉场景观测中还原接触状态。把接触特征神经网络作为环境感知模块,结合基于接触特征重建的通用解析优化抓取框架,系统实现了零样本适配,可让二至五指的铰接式机械手在杂乱、无结构、密集堆叠的三维环境中稳定抓取。
团队表示,这是首个实现跨不同机械手零样本稳健抓取泛化的学习与优化混合算法框架,在三维空间达到先进的抓取表现,且采用低成本传感方案,具备实际部署潜力。
论文通讯作者为徐青松,第一作者为澳门大学工程系博士后研究员 Wang Xianli,澳门大学工程系教授 Tam Lap Mou 同为作者。研究获中国国家自然科学基金、澳门特别行政区科学技术发展基金与澳门大学资助。
(来源:澳门大学)
University of Macau Team Tackles Robotic Grasping: New Framework Enables Zero-Shot Stable Grasping Across Robotic Hands, Published in Nature Machine Intelligence
A research team led by Professor Xu Qingsong in the Faculty of Engineering at the University of Macau (UM) has achieved a breakthrough in the field of universal robotic manipulation. The team has developed a comprehensive framework for universal robotic grasping that can be adapted to complex scenarios, enabling the rapid deployment of customised and commercial robotic hands, and offering an innovative technical solution for advancing flexible automated production, medical assistive robots and service robotics. The research findings have been published in Nature Machine Intelligence.
As intelligent service robots are deployed in an increasing number of scenarios, two issues with existing manipulation algorithms are hindering their large-scale commercial application: insufficient adaptability across hardware platforms, and poor robustness in complex environments with limited sensory perception. Traditional deep learning models that rely on monocular depth vision struggle to accurately characterise the physical contact between robotic hands and objects, and show significant limitations in generalisation when performing grasping tasks with multi-fingered, multi-degree-of-freedom robotic manipulators of varying models.
To address these challenges, the team decoupled the kinematic model of robotic hands from the interactive contact states during manipulation, establishing robust and deployable contact state features that are independent of specific robotic hand models. Using existing paired grasping datasets, the team constructed a large-scale, device-agnostic database of decoupled contact features and trained neural networks to restore contact states from visual scene observations. By integrating a contact feature neural network as the environmental perception module with a universal analytical optimisation grasping framework based on contact feature reconstruction, the system achieves zero-shot adaptation, enabling all two- to five-fingered hinge-type robotic hands to perform stable grasping operations in cluttered, unstructured and densely stacked three-dimensional environments.
The study proposes the first learning-optimisation hybrid algorithm framework to enable zero-shot robust grasping generalisation across different robotic hands in highly cluttered scenarios, achieves state-of-the-art grasping performance in three-dimensional space, and uses a low-cost sensing scheme with great potential for practical deployment.
The corresponding author of the study is Xu Qingsong. The first author is Wang Xianli, a postdoctoral fellow in the UM Faculty of Engineering, and Tam Lap Mou, professor in the UM Faculty of Engineering, is also an author. The research was supported by the National Natural Science Foundation of China, the Science and Technology Development Fund of the Macao SAR, and the University of Macau.
(Source: University of Macau)
来源:澳门大学
发布:GSM·美国(发布链接)
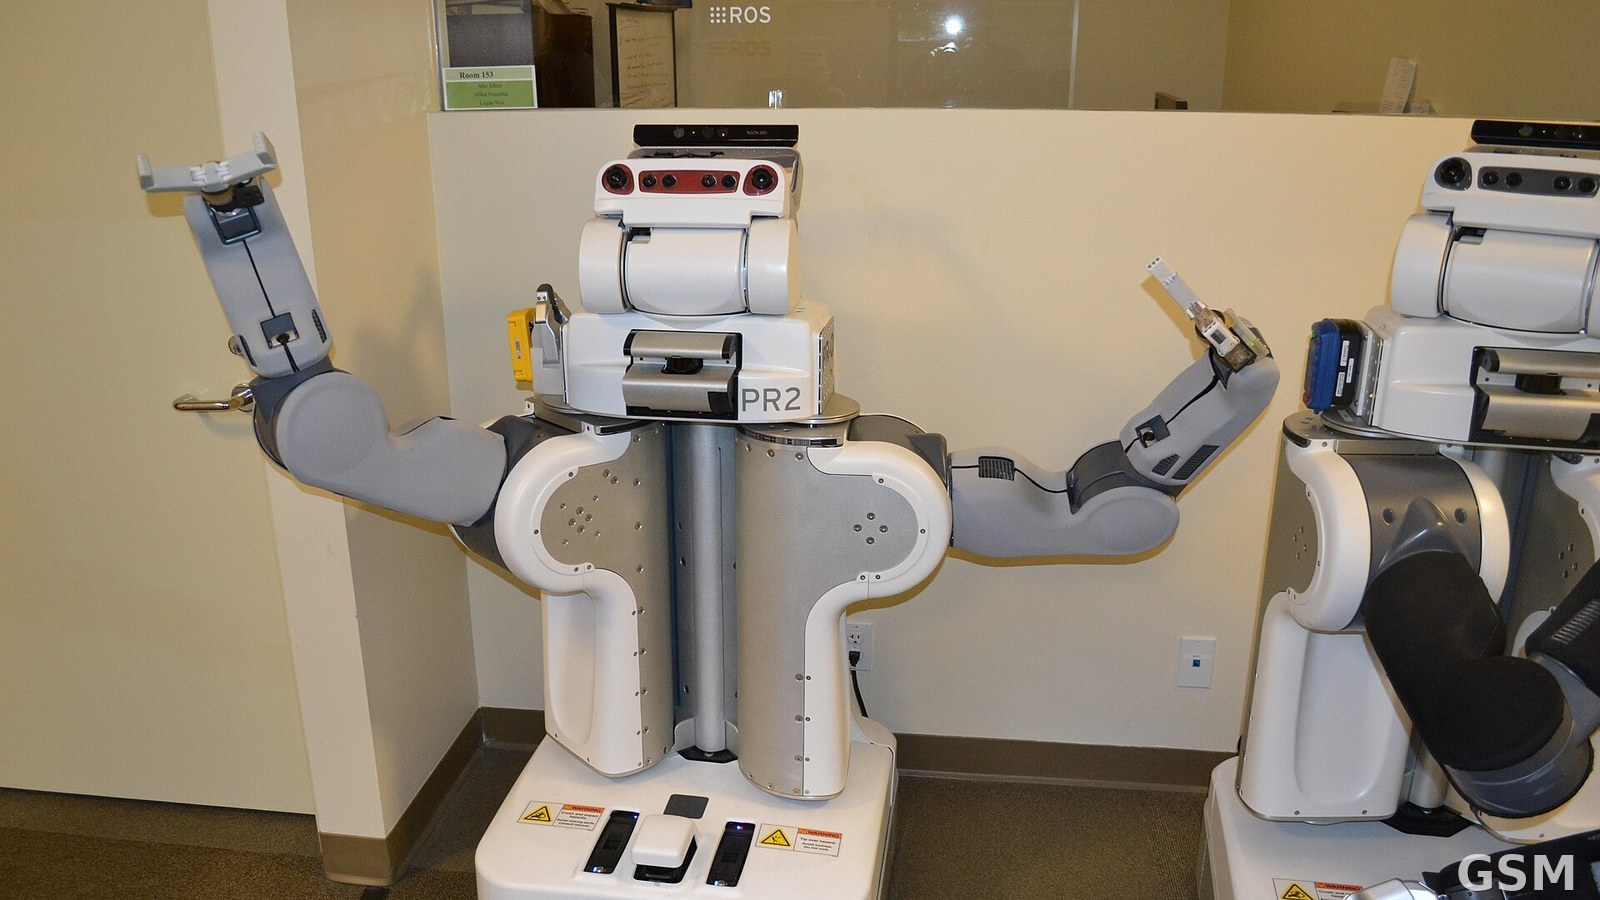
图片来源:图:配备先进抓取手的 PR2 机器人(机器人抓取研究资料图)。Oleg Alexandrov 摄,CC BY-SA 3.0,经 Wikimedia Commons。 / Photo: A PR2 robot with advanced grasping hands (file photo on robotic grasping research). Photo by Oleg Alexandrov, CC BY-SA 3.0, via Wikimedia Commons.
GSM Global · 本篇英文版 English edition of this story